Introduction
Quadric surfaces are given in as the set of points satisfying a quadratic equation in three variables. The most general form of equation is:
After applying a rigid motion to , any such equation can be converted to one of these simpler equations:
The surfaces satisfying Equation (1) include spheres, cones, cylinders, ellipsoids, and hyperboloids. The surfaces satisfying Equation (2) include elliptic paraboloids and hyperbolic paraboloids.
The surface type can be deduced from the coefficients or .
One way to study equations of quadrics is to consider their traces, which are conic sections in two variables given by setting the third variable constant. A trace is the intersection of the quadric surface with the plane determined by the constant variable.
Introduction (part 2)
Rotating away cross-variable terms of a quadric
Libretext link for an explanation of how to eliminate cross-variable terms by applying rotations.
Spheres
The general equation of a sphere in with center at and radius is given by:
This equation is justified by the generalized Pythagorean theorem for three dimensions.
Spherical coordinates parametrize a sphere at radius . The angle is the standard angle in the -plane, and the angle measures declination from the north pole. These coordinates may be converted to standard coordinates:
Warning
Note that give coordinates for points in , but the numbers are not vector components. Do not perform vector operations componentwise on !
Cylinders generalized
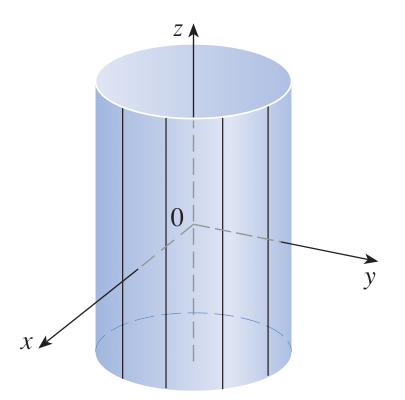
A simple cylinder is a tube extended in the -coordinate with a circle for each -cross-section. No constraint on the -coordinate is needed, and the -coordinates satisfy the equation of a circle: .
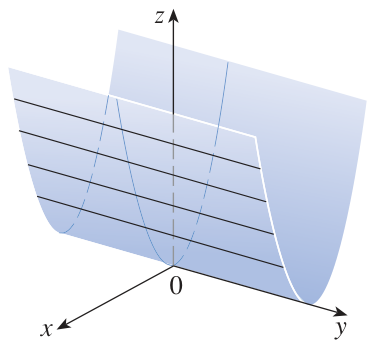
More generally, the set of points satisfying an equation in terms of only two variables gives a generalized cylinder, extended in the coordinate of the missing variable. For example, gives a parabolic cylinder extended in the -coordinate:
For any cylindrical surface, it is possible to find new coordinates in which the surface is defined using only two of them.
Note that quadric surfaces written with two variables are generalized cylinders, but most generalized cylinders are not quadratic!
Ruled surfaces
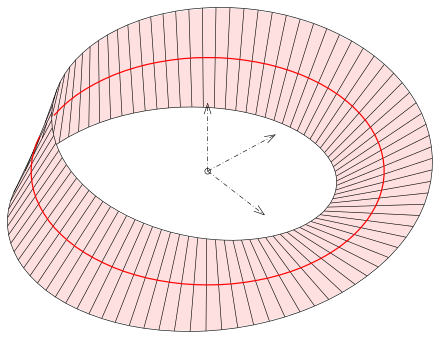
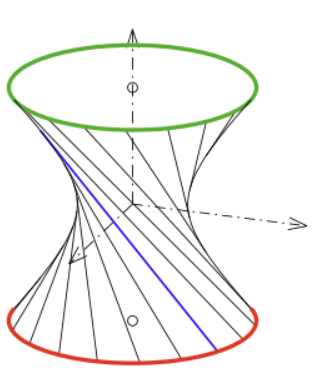
Generalized cylinders are examples of ruled surfaces, which are surfaces created by the smooth motion through space of a straight line. For generalized cylinders, the lines must remain parallel, i.e. the motion must be perpendicular to the lines.
Other ruled surfaces that are not generalized cylinders:
Helicoid:
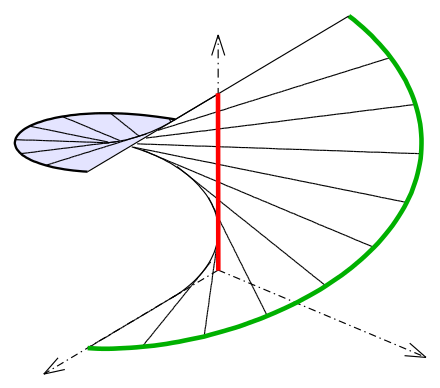
Mobius strip:
Hyperboloid:
Quadrics - ellipsoids
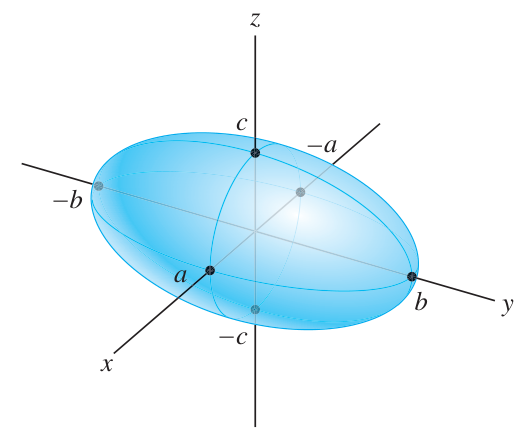
Ellipsoids are quadrics surfaces of type with and .
Under these conditions, the quadric equation can be rewritten into a more expressive form:
As with an ellipse, the constants determine the three axis lengths of the ellipsoid. When , the ellipsoid is actually a sphere.
Quadrics - hyperboloids
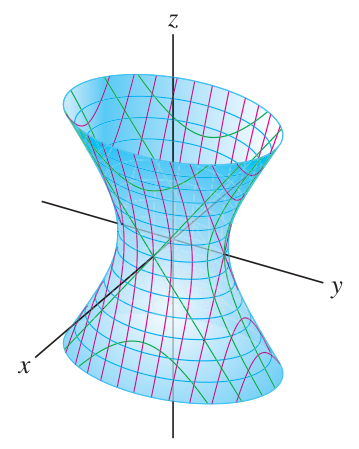
Hyperboloids are quadric surfaces of type with one of less than , and the other two greater.
By exchanging the roles of and rewriting, we can assume the equation takes the form:
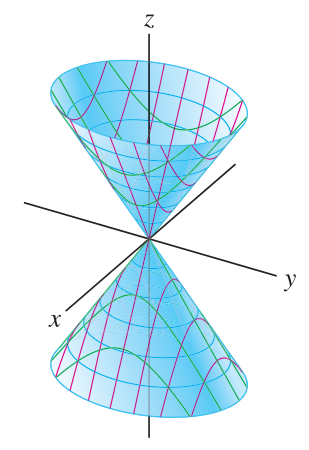
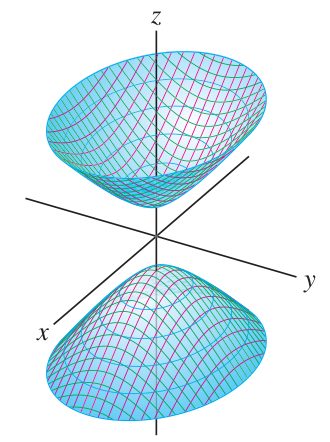
There are three kinds of hyperboloids: cones, hyperboloids of one sheet, and hyperboloids of two sheets. They are given by equations with , , and , respectively.
One-sheeted paraboloids include a circle at , which is possible because . Shrinking shrinks the circle at until it is a point at (creating a cone, or more descriptively, a double-cone), and when goes negative, the surface does not exist at .
:
:
:
Quadrics - paraboloids
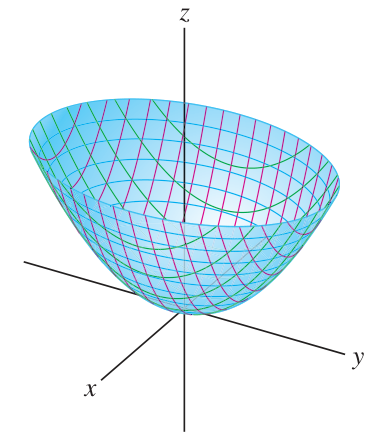
Paraboloids are quadric surfaces of type . For this type, , so we may divide by and thereby assume . We can rewrite the general form:
The paraboloid is elliptic when both signs are plus (opening up) or minus (opening down). The paraboloid is hyperbolic when the signs are opposite.
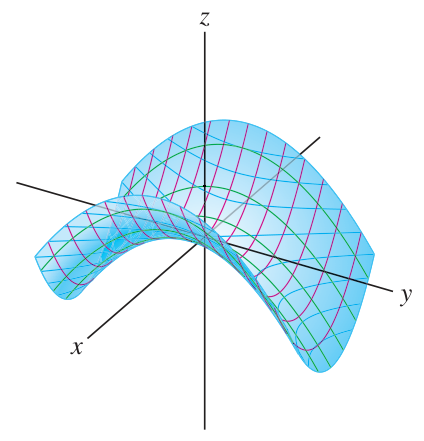
Elliptic and hyperbolic paraboloids are often useful to illustrate optimization methods. A paraboloid has a horizontal tangent plane at the bottom (both signs positive), or the top (both negative), or the saddle point (opposite signs).
:
: