Introduction
A vector-valued parametric curve in may be given in terms of component functions by . When the component functions are differentiable, then is also said to be differentiable, and the derivative function is . Applying the same logic repeatedly, one obtains higher derivatives .
Derivative rules for parametric space curves
Given vector functions, and a scalar, and a scalar function (all differentiable), then the standard derivative rules for algebraic compositions of functions determine rules applying to vector operations: e
- Sums:
- Constants:
- Scalar products:
- Chain rule:
Moreover, by considering the component formulas for vector products, one finds derivative rules for vector products analogous to the rule for a scalar product:
- Dot product rule:
- Cross product rule:
Derivative rules for parametric space curves (part 2)
Constant norm vector functions
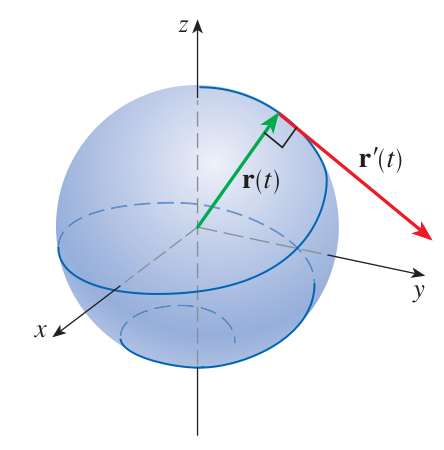
When a vector-valued parametric function has constant norm , the vector is necessarily perpendicular to its own derivative:
This fact is often applied to the case of a unit vector. Intuitively, a unit vector gives a direction as a point on the unit sphere. An infinitesimal change of this direction will lie in the tangent plane to the sphere, which is perpendicular to the sphere, and thus perpendicular to the original vector.
Tangent and normal vectors
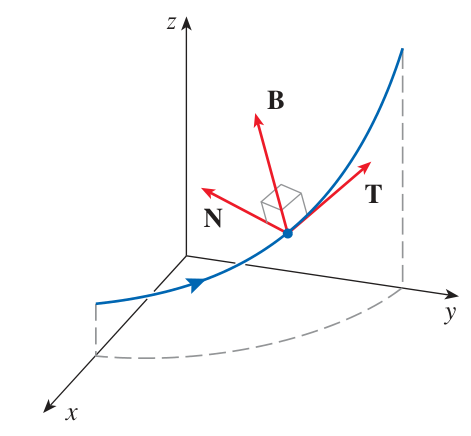
The tangent vector of a parametric curve is just the derivative of as a vector-valued parametric function. It is tangent to the curve:
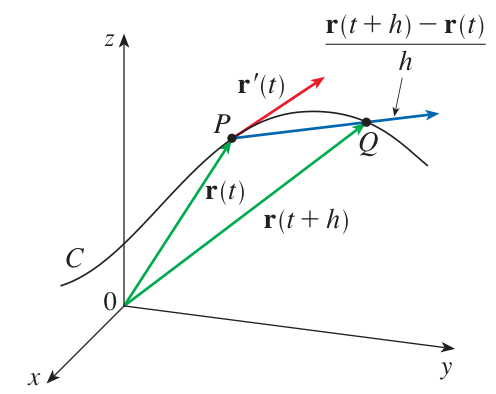
When the curve is non-stationary, i.e. , then its tangent vector determines a unit tangent vector which is typically written . This vector represents the direction of travel of a particle traversing the curve.
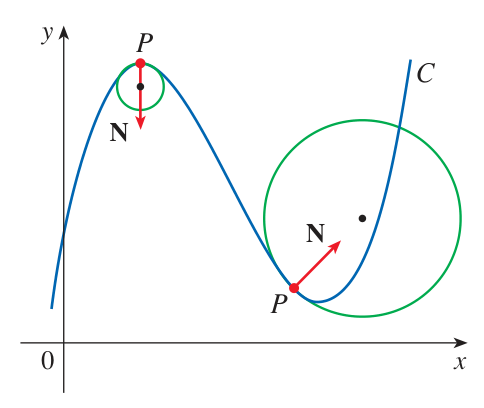
When the component functions are twice differentiable, the unit tangent has a derivative . Where the curve is non-straight, i.e. , then determines a unit normal vector , also called the principal normal vector.
and are perpendicular
Since has a constant norm of one, we know that at all times.
Distance traveled, speed
To improve the expression of various formulas, we use the notation:
The distance traveled function is given for a parametric curve in by:
It follows from the Fundamental Theorem of Calculus that:
This quantity is called the speed of travel at time .
Curvature
The curvature of a space curve is defined as the rate of change of the unit tangent vector with respect to distance traveled.
For curves in the plane, a single quantity, the angle of inclination , is sufficient to characterize the heading direction, and the curvature is given by . For curves in space, the unit vector plays the role of , giving the heading direction. (In spherical coordinates, a point on the unit sphere is determined by two angle quantities , .) The rate of change of heading is best described as a vector quantity whose norm gives the curvature:
The curvature quantifies a geometrical property of the curve image, and it does not depend on the parametrization. This follows because and are both functions of the curve image. (Plus a chosen direction of travel along the curve that determines signs, but the sign of cancels the sign of ). A point on the curve may be specified by the parameter or by the arc length , so may be considered a function of or of .
Using the fact that , we find that the rate of change of the unit tangent with respect to the parameter can be expressed in terms of speed, curvature, and the unit normal:
Acceleration decomposition
The acceleration vector of is defined as its second derivative with respect to time: .
Since is defined using , and is defined using , we expect a relation between and . Indeed we have:
This follows because , so the product rule gives:
Efficient curvature formula
The quantity in the denominator of often makes the derivative annoying to compute. It is possible to avoid this derivative by using further reasoning to develop an alternate formula for . First, observe that:
Since is a unit vector, it follows by taking norms that:
Efficient formula for
The decomposition of can also be used to give an efficient formula for :
We can see this by multiplying the decomposition by :
Dividing both sides by the norm gives the desired formula.
Acceleration decomposition (part 2)
Acceleration decomposition
Given that and are orthogonal unit vectors and is a linear combination of them, it is appropriate to name the components of according to the decomposition:
with and . So is the component of acceleration in the direction of travel, which by the definition is also just the rate of change of the scalar speed with respect to time; and is the component of acceleration in the normal direction, perpendicular to the direction of travel.
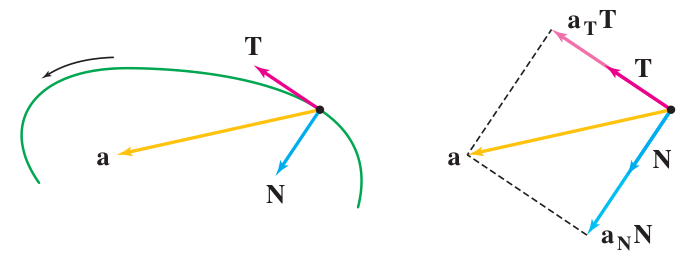
Acceleration lies in span of and
The fact that can be written as a linear combination of and says something about . In fact it gives a way to characterize : it is the unique direction perpendicular to that is determined by the part of perpendicular to .
Acceleration decomposition (part 3)
Going deeper
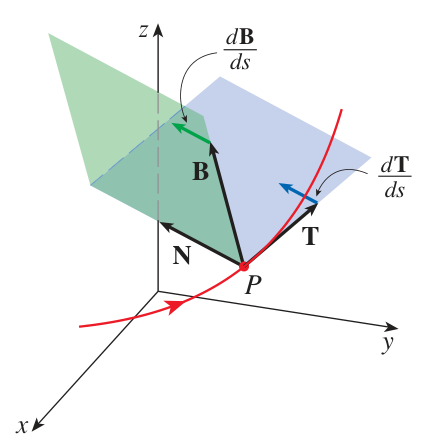
The space of vectors perpendicular to is a plane, so is not unique with the property that . It is unique in containing the new direction of . The plane given by all linear combinations of and is called the osculating plane.
Another unit vector may be defined by , and we also have . It is called the ‘binormal’ vector. The collection of pairwise orthogonal unit vectors forms a special basis naturally arising from the parametric curve which is called the ‘Frenet-Serret frame’, or sometimes the ‘ frame’.