Gromov-Hausdorff distance
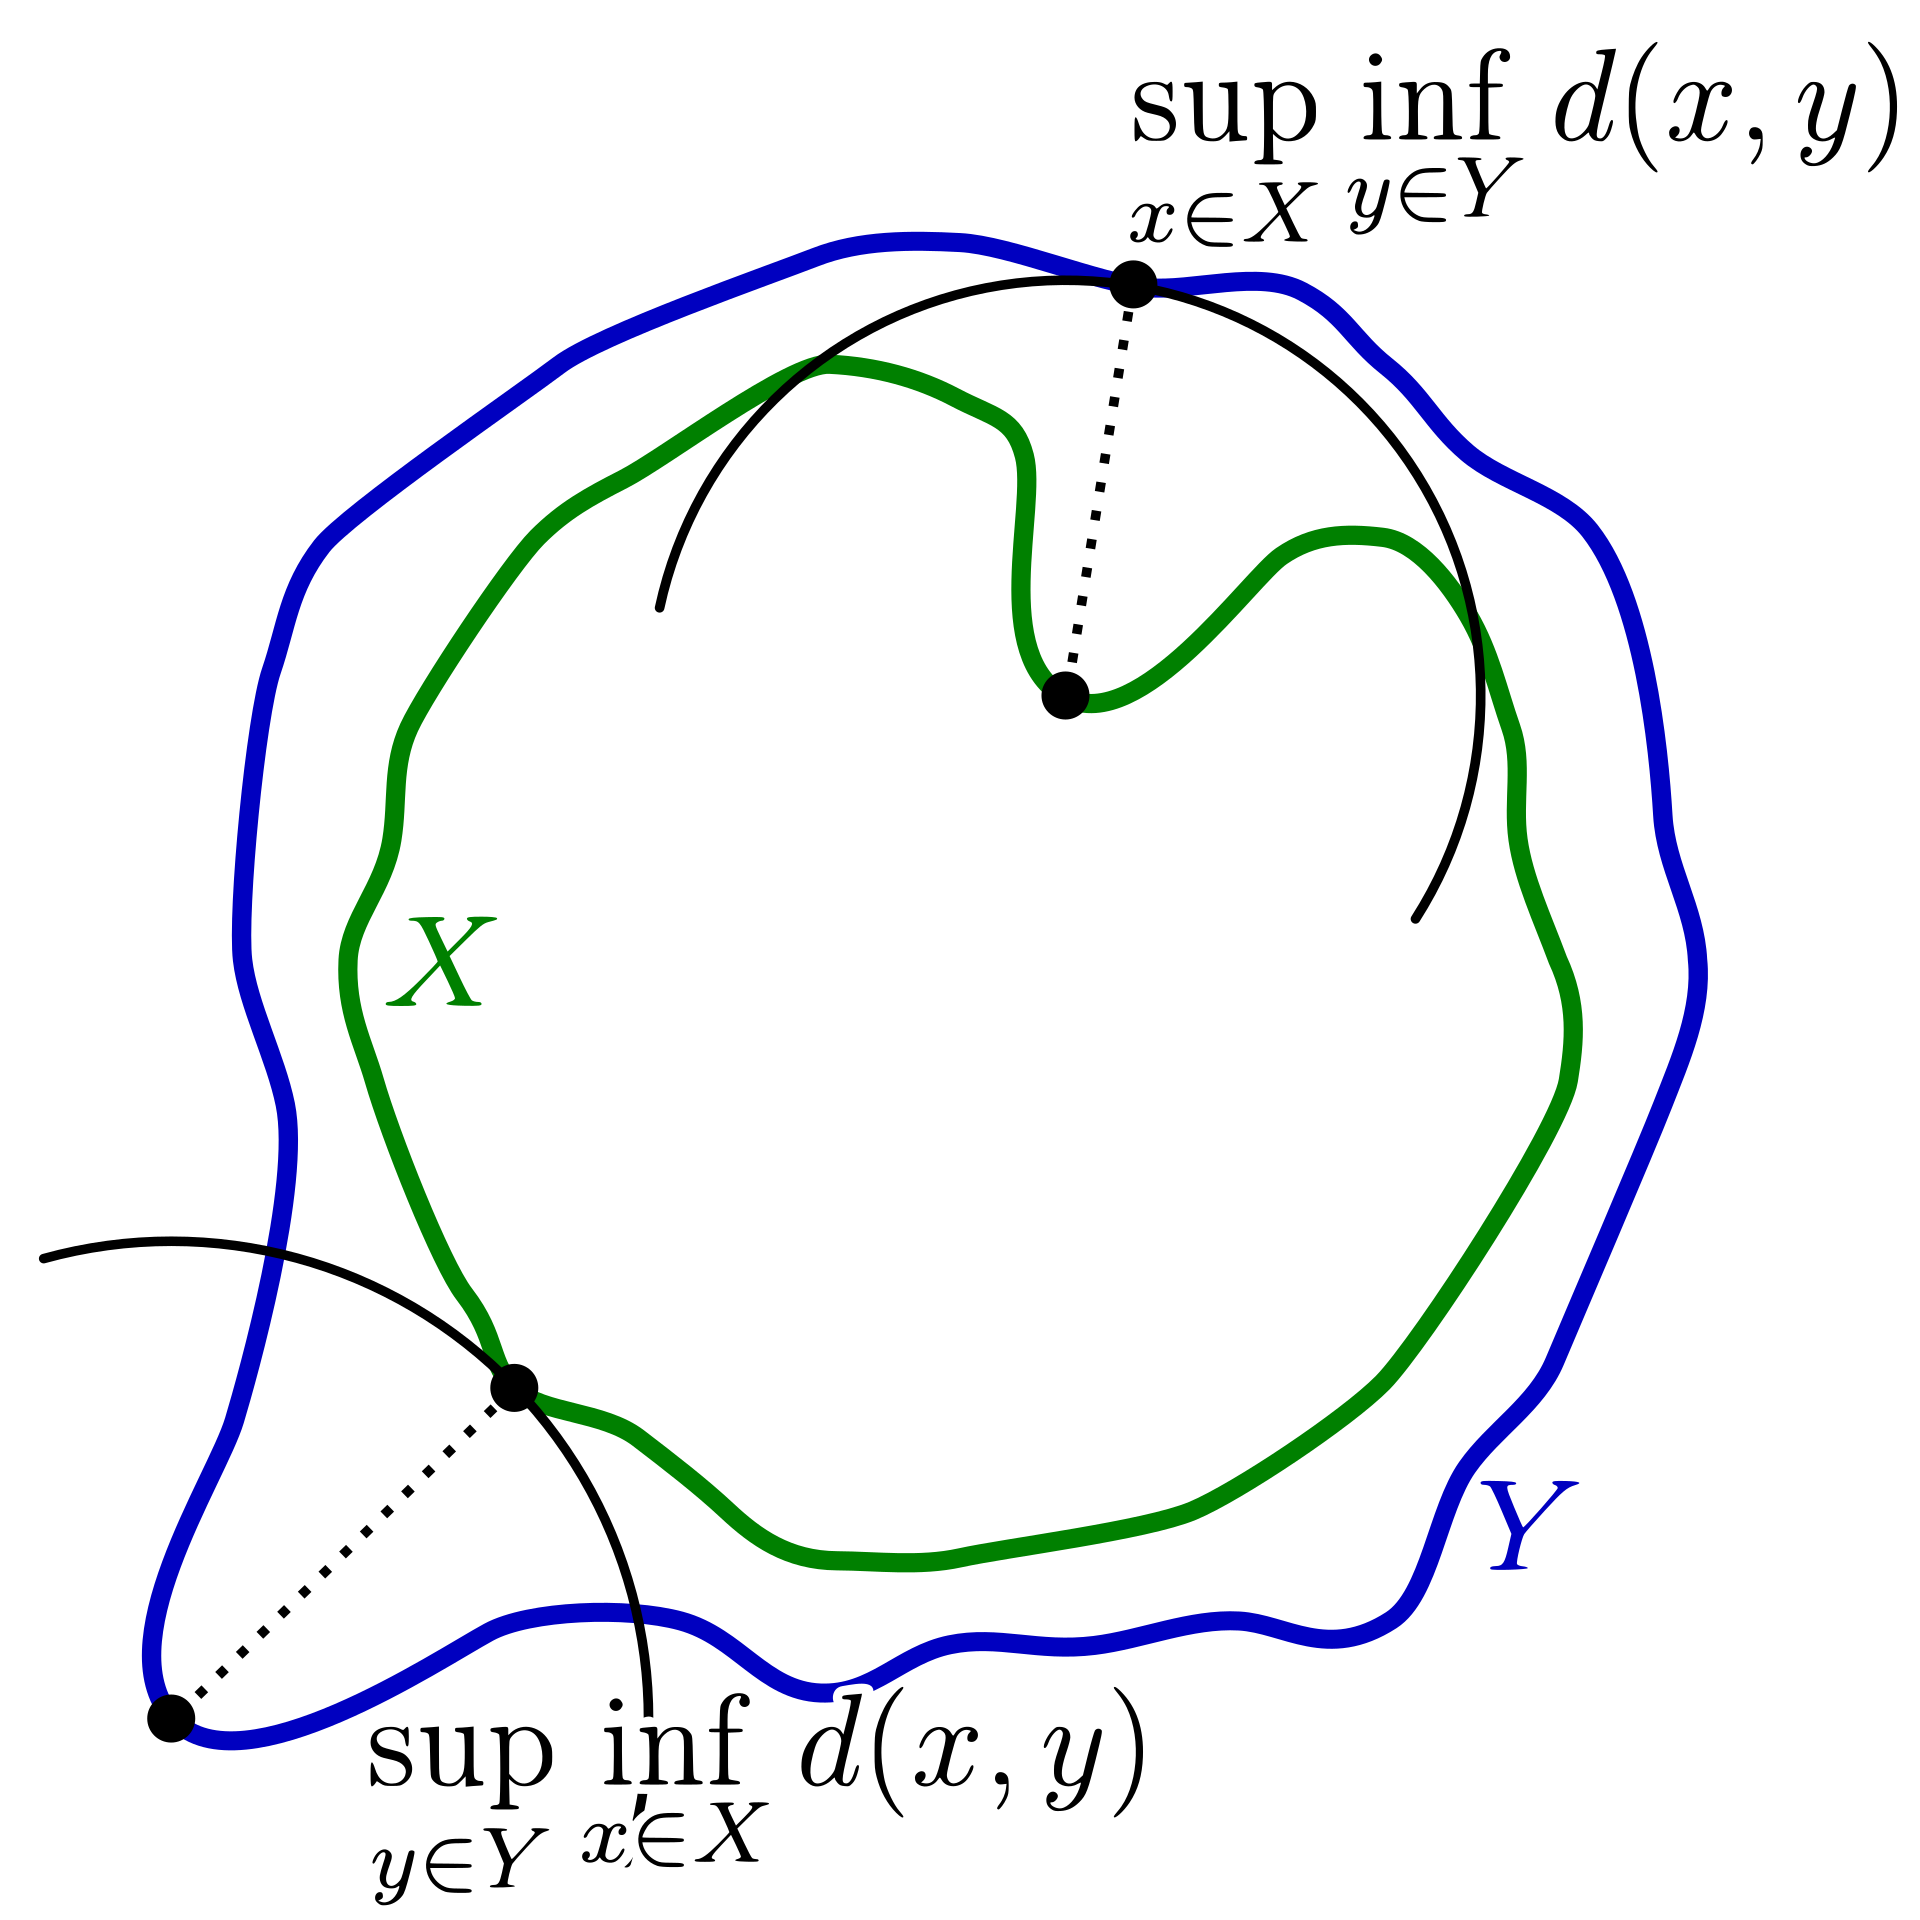
Hausdorff distance
Suppose and are subsets of a metric space .
The Hausdorff distance is:
Here:
- smallest distance to
- smallest distance to
Therefore:
- within , how far away can you get from ?
- within , how far away can you get from ?
Gromov-Hausdorff distance
Suppose and are compact metric spaces and is some fixed compact metric space.
The Gromov-Hausdorff (GH) distance is:
where , are isometric embeddings of , into .
Notice that this definition is relative to .
Dendrogram
Persistent homology describes the clustering of point-cloud data.
The GH distance frequently serves as a pure math benchmark. Given finite sets of points , the distance is a measure of similarity of the shape of the point clouds and .
The GH distance cannot be computed efficiently (if at all), so other measures of similarity for point clouds are useful.
Desiderata for measures of point-cloud similarity:
- Quantifies topological and geometric features
- Distinguishes features from noise
- Is computable
- Recognizes when features are close in the GH metric
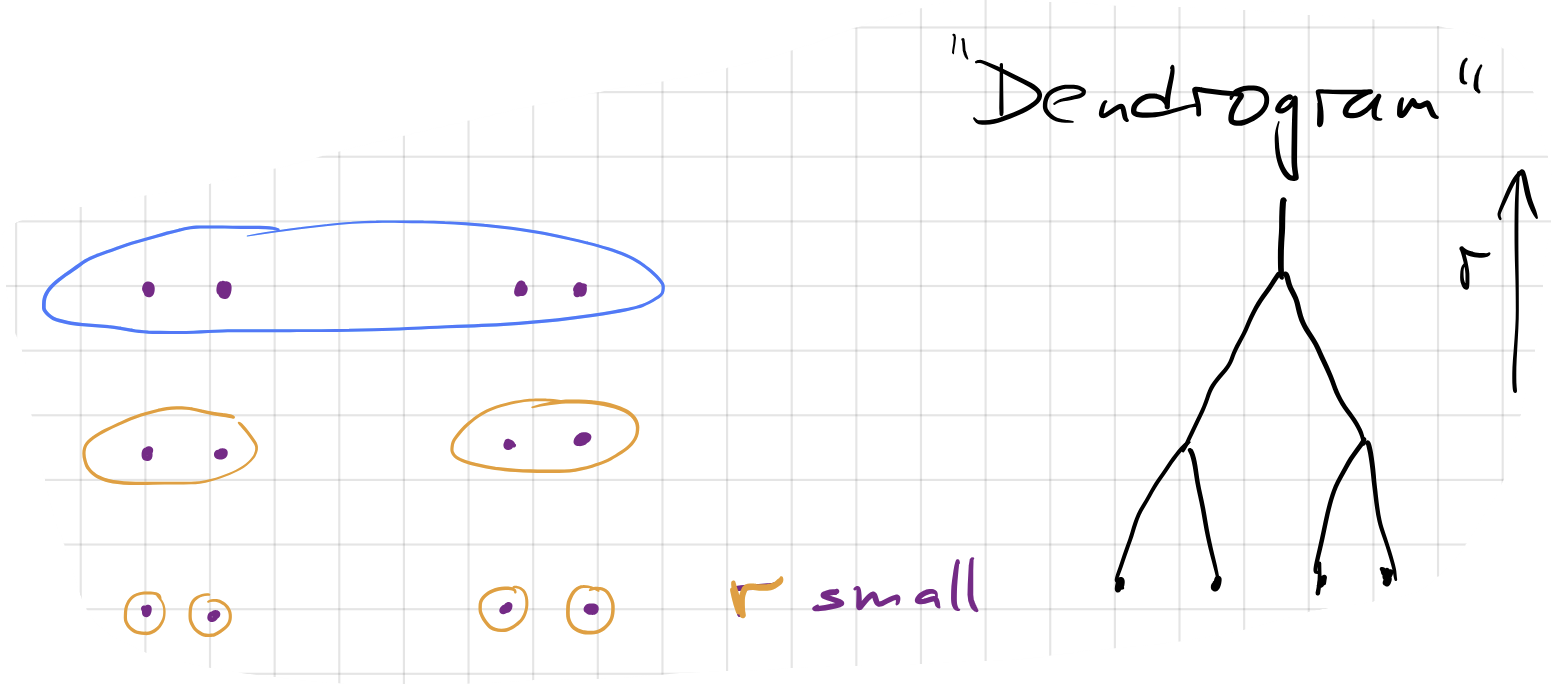
Suppose we have a finite set of points for a metric space .
Fix . Define a relation when .
Let be the transitive closure of . This is an equivalence relation (generated by ) which partitions into equivalence classes. Members of each equivalence class can be obtained from one another by a sequence of “hops” between points no more than apart.
Draw a tree diagram with a junction at each where distinct clusters are joined:
Filtrations
Filtered simplicial complex
A filtered simplicial complex is a complex with a collection:
where each is a simplicial complex which is a subcomplex of .
(The vertices and simplices of a subcomplex must be vertices and simplices in the supercomplex.)
Filtered space
A filtered topological space is a collection of spaces indexed by with continuous maps:
and these maps satisfy a transitivity compatibility:
It is sometimes convenient, if a little ungainly, to consider a filtered simplicial complex as a filtered space where is a simplicial subcomplex of whenever . Such a filtered space changes only at discrete values of .
Vietoris-Rips complex
Vietoris-Rips complex
Let be a finite set of points in a metric space .
The Vietoris-Rips complex is the complex whose vertices are the points , and whose -simplices are those subsets with points all of which are pairwise less than apart:
The VR complex is a filtered space (filtered complex) because:
Notice that the VR complex and the Čech complex include the same 1-simplices: a simplex is in the VR complex if , and in the Čech complex if . These conditions are equivalent, at least in .
Pairwise vs. mutual intersection
- The VR complex includes simplices for points which pairwise intersect.
- The Čech complex includes simplices for points which mutually intersect.
For example:
The three blue circles all intersect pairwise, so is in the VR complex, but they don’t mutually intersect so this simplex is not in the Čech complex.
On the other hand, the four green circles do not intersect pairwise. The VR complex and the Čech complex are the same in this case.
VR complex computability
Since the VR complex depends only on the data of pairwise distances between points, it is very easy to compute.
Čech and VR containments
For any point cloud , we have:
- inclusion as subcomplex
- inclusion as subcomplex
The first is true because any mutual intersection implies the pairwise intersections.
The second is true because any pairwise intersection of balls implies that the balls extend to cover other centers. So the centers of all points are in the -balls of each of the others, thus the centers are in the mutual intersection.
Persistent homology, barcodes
Persistent homology
Let be a filtered simplicial complex.
Fix . For any , define:
Whenever there is a map and this induces linear maps on homology:
These satisfy .
The persistent homology of is the collection of vector spaces and linear maps .
Persistent homology is defined for any filtered simplicial complex. For example, we can take persistent homology of the Čech complex or of the Vietoris-Rips complex.
Persistent VR homology - Structure Theorem
Let for be the persistent homology of the VR complex of a point cloud .
Fix . Then has a canonical decomposition as a direct sum of persistence intervals:
Persistence interval
For any with and , define:
with (linear) filtration maps given by when .
Illustration - barcode and persistence diagrams
Barcode diagram:
- Each receives a horizontal bar starting at , ending at .
- Bar colored according to degree in
Persistence diagram:
- Each receives a dot placed at
- Horizontal ‘birth’ axis, vertical ‘death’ axis
- Dots colored according to degree in
Barcode basis
We would like to understand the direct sum decompositions like the one in the example of the point cloud square:
Understanding such a decomposition amounts to determining a basis of homology classes that have lifespans described by the persistence intervals.
We have:
A basis for is the equivalence class of all vectors in which are not in the span . For example, or or .
Barcode diagram for :
Now consider . Cycles in are generated by 1-simplices which are sets of two points that are apart.
Consider again the square point cloud:
For , we have .
For , we have .
For , we have 4 additional 2-simplices (all combinations of 3 points).
The square will the boundary of the difference of two of the 2-simplices (complementary triangles), so the homology class of the square vanishes when reaches .
Barcode diagram for :
Thus: