Vectors
Vector space: addition and scaling
Vector space - addition and scaling
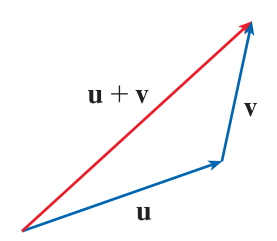
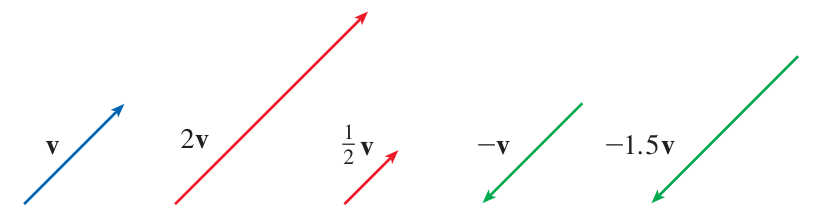
A vector is an element in a vector space, which is a collection of objects supporting addition and scalar coefficients.
Vector space operations
- is a vector when
- is a vector when
Properties of vector operations
- Commutativity:
- Associativity:
- Distributivity:
- Zero vector:
The elements also satisfy obvious properties like:
and andScalars
Link to original
Scalars (“scal-ers”) could be taken in any field, but for this class, they are just real numbers .
Components of vectors
Components of vectors
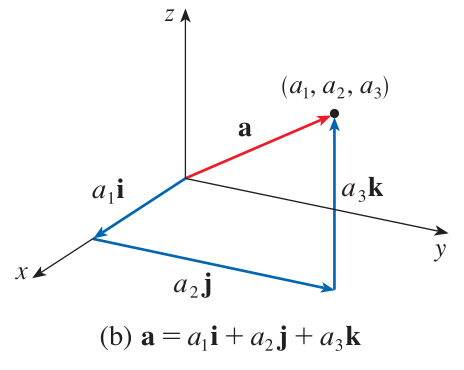
In this class we consider vectors in the plane and vectors in space .
Vectors in the plane are ordered pairs with .
Vectors in space are ordered triples with .Addition is componentwise:
Scalars act by components too:
(Similarly for vectors in space.)Standard basis vectors
These special vectors have their own symbols:
Components
Most often the word ‘component’ of a vector refers to one of the numbers in the ordered sequence or .Sometimes ‘component’ refers to the basis vector scaled by this number, e.g. .
Notice that we always have , which is the reason ‘component’ is sometimes used in this second way.Other bases
It is possible to select a different set of special vectors, e.g. , having the property that any vector can be written uniquely as a linear combination in the same way: . Any such set is called a basis, and the in this case are called components in the basis . This topic is considered further in Linear Algebra.Coordinates
Mathematicians say ‘components’ for the parts of a vector, and ‘coordinates’ for the quantities that are used to identify points of space. Since the spaces and are vector spaces, the tuples or actually give coordinates and vector components!In more general curved spaces, points cannot be “added together,” so this relation between coordinates and components breaks down.
Link to original
Geometric vectors
Geometric vectors
It is possible to consider vectors purely geometrically as the combined data of direction and magnitude in space.
(Provided one has defined space purely geometrically, which nobody does.)Link to original
Products of vectors
Introduction
Vector spaces often come with additional product operations between vectors.
Link to original
Dot product
Dot product
The vector space (any ) comes with an inner product, also called the dot product or scalar product. Every inner product satisfies basic rules:
Algebraic properties
Component definition
The dot products for and are defined using components:
Norm
The dot product of a vector with itself gives a number called the (norm or length or magnitude) squared:
The terminology is justified by the Pythagorean Theorem in :
Link to original
Exercise
01
Link to originalParallelogram identity
Let and . Compute and and and . Show that:
Dot product (part 2)
Geometry
The dot product scalar provides information about the geometric relationship of two vectors.where is the angle between and .
Proof: The rules for dot product imply that:On the other hand, the Law of Cosines for the triangle with sides gives:
It is worth noticing that the norm determines the dot product:
The formula for has qualitative geometrical consequences:
Link to original
- If then and are orthogonal (perpendicular)
- If then and form an acute angle
- If then and form an obtuse angle
- If then and are parallel
Exercise
02
Link to originalAngle between vectors
Find the angle between and .
Exercise
03
Link to originalOrthogonality by hand
Determine which pairs of and and are orthogonal.
Exercise
04
Link to originalAcute, orthogonal, or obtuse?
Are the angles between and and obtuse or acute?
Exercise
05
Link to originalDot product via unit vectors
Compute the dot product of and .
Dot product (part 3)
Unit vectors
A vector with is called a unit vector.
For example, are unit vectors.Thinking geometrically, a unit vector carries the information of direction. One could call them ‘direction vectors’ instead.
Any vector can be renormalized to create a new unit vector by dividing out its length:
Some texts, especially in physics, use the notation for this unit vector .Projection
The dot product is a quantity telling how much one vector aligns with another.
The dot product of two unit vectors is where is the angle between them.One can use the dot product to find the components of a vector in the standard basis. Say is any vector. Then:
This is because .
More generally, one defines the projection of along (projection along the direction of ) using the dot product:
The scalar coefficient is called the parallel component of along . (Or, sometimes, is called the component.)
The projection points in the direction of , and it says how much of lies in that direction.
Another vector called the perpendicular component is given by subtracting the parallel part:
It is called ‘perpendicular’ because:
Link to original
Exercise
06
Link to originalProjection by hand
Let and .
- (a) Find the projection of to the direction of .
- (b) Write the vector in terms of parts parallel and perpendicular to .
Dot product (part 4)
Cauchy-Schwarz inequality
Link to original
The Cauchy-Schwarz inequality says that for any vectors , , we know:
Exercise
07
Link to originalCauchy-Schwarz
Prove the Cauchy-Schwarz inequality using the angle formula.
Dot product (part 5)
The Cauchy-Schwarz inequality is very important in math. There is a version of this inequality in many other settings where it is harder to prove.
Triangle inequality
Link to original
The Triangle inequality says that for any vectors , , we know:
Exercise
08
Link to originalCauchy-Schwarz Triangle
Prove the Triangle inequality using the Cauchy-Schwarz inequality and an expansion of with the dot product.
Exercise
09
Link to originalOrthogonality identity
Suppose that vectors and satisfy . Show that they must be orthogonal.
Cross product
Cross product
Another product is defined for vectors in called the cross product. It is also called the vector product. The simplest definition is in terms of components:
assuming that and .
There are some mnemonic formulations that can be helpful:
Or:
“Twist the others, minus in the middle.”Or:
Or:
This is a determinant. The first row of vector entries should be treated as if scalars when taking this determinant.
Link to original
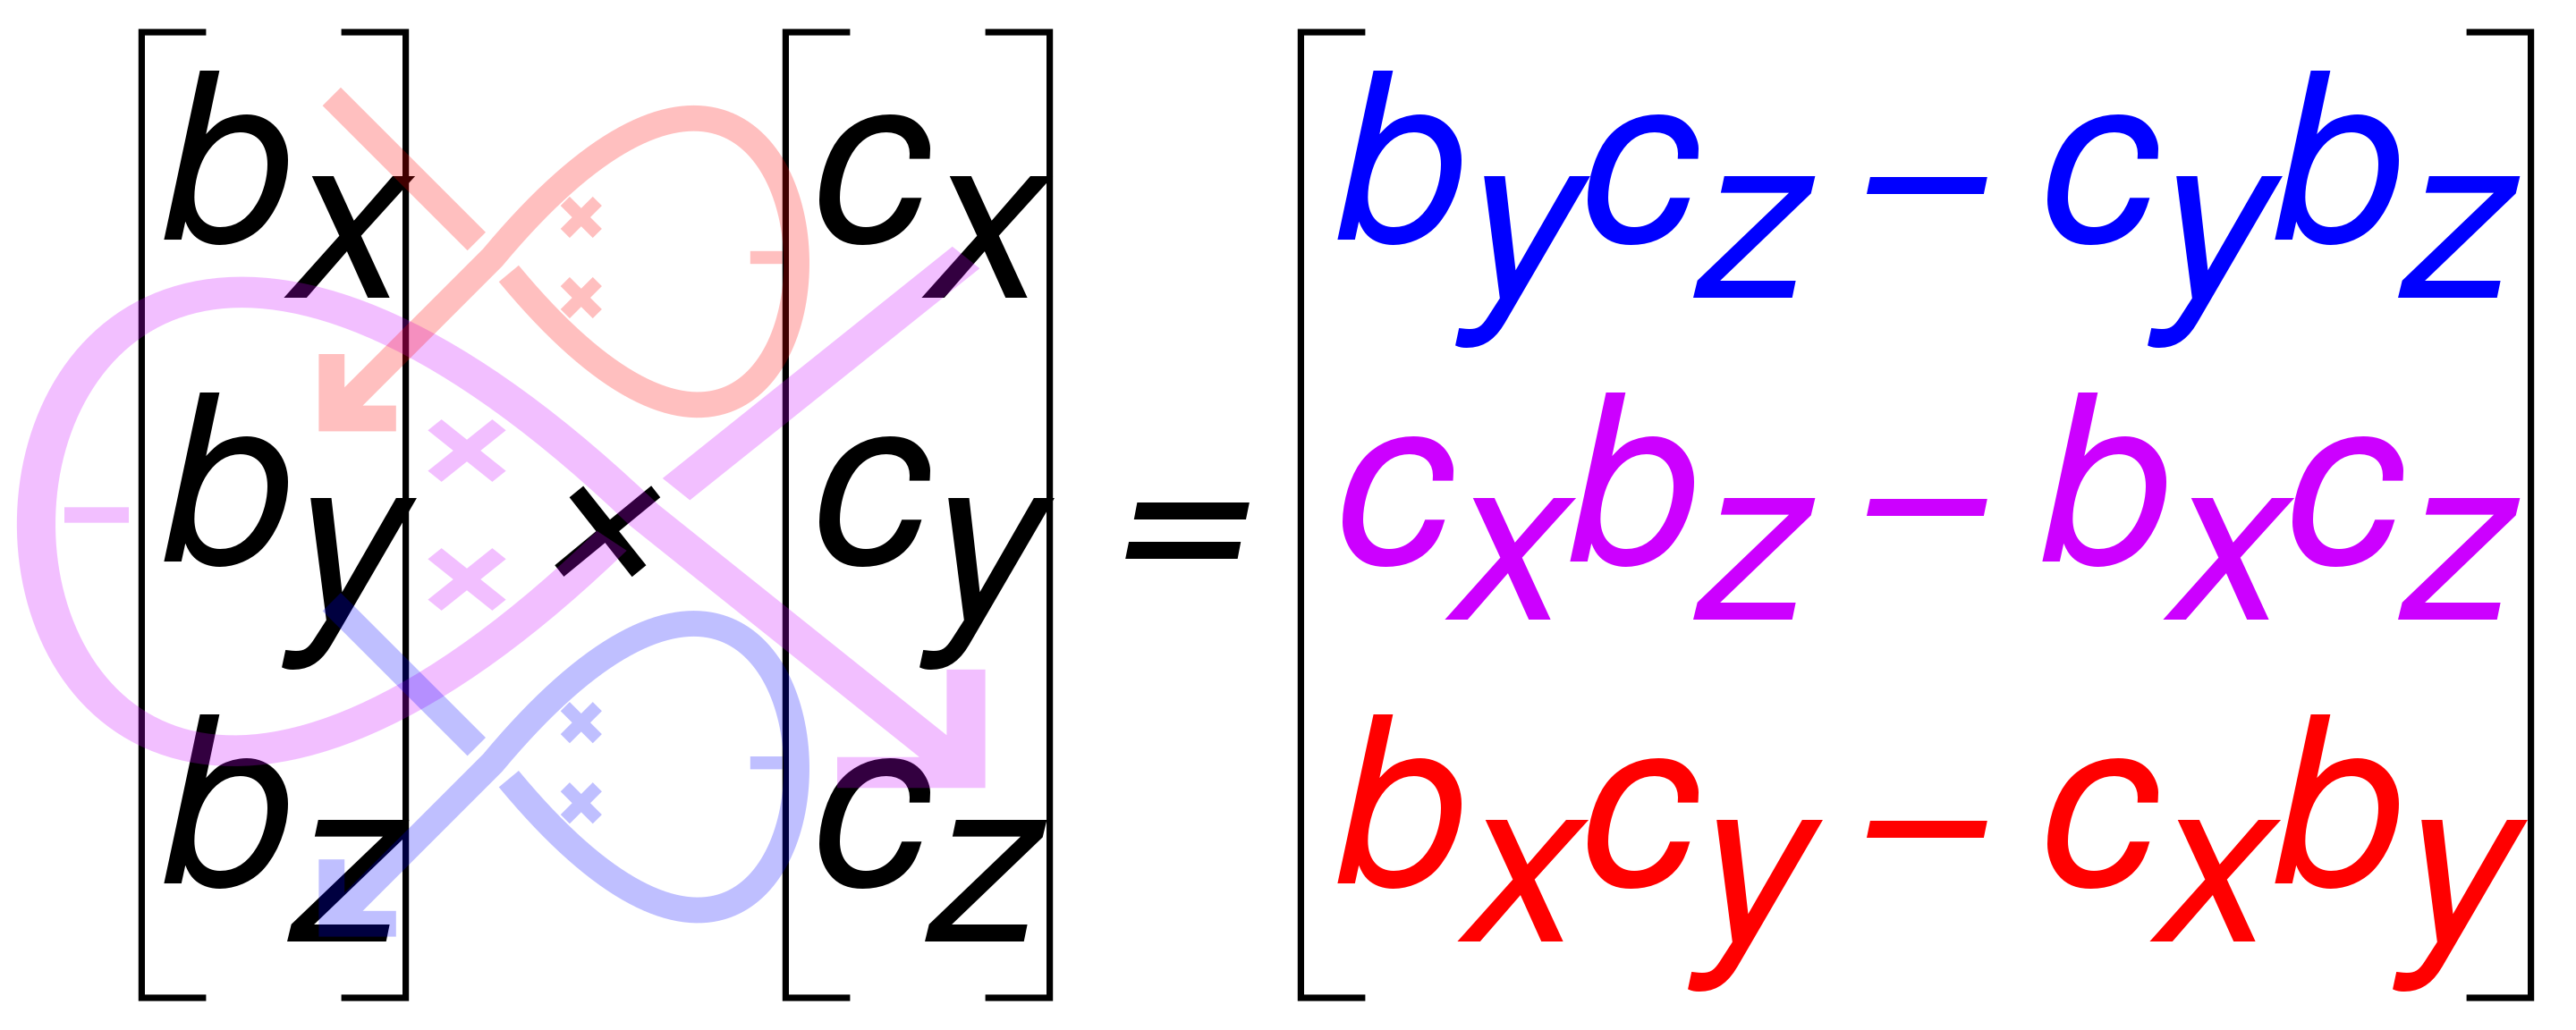
Exercise
10
Link to originalCross products by hand
Let and . Compute in coordinates:
- (a)
- (b)
- (c)
Cross product (part 2)
Algebraic properties
The cross product is not commutative and not associative. But it does satisfy some relations:
- ( thus )
- ( thus )
- implies for some
Geometry
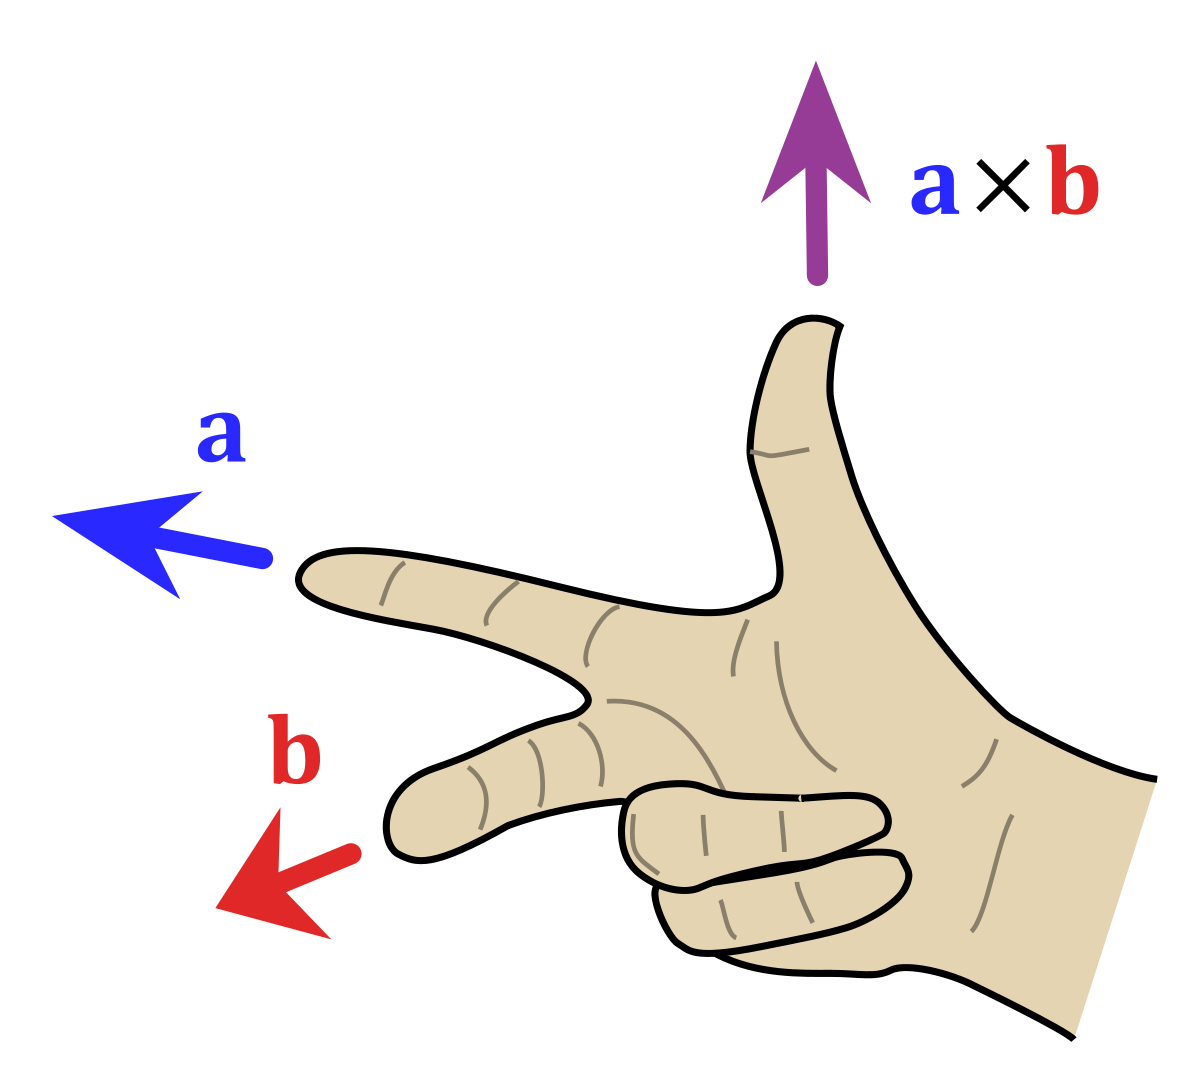
The norm of the cross product satisfies an angle formula analogous to that of the dot product:The direction of the cross product is perpendicular to the plane spanned by and it creates a right-handed system when combined with .
I.e. is right-handed.The norm of the cross product is also the area of the parallelogram formed by .
Link to original
Exercise
11
Link to originalCross product left-handed system
Use the cross product to find a unit vector that is perpendicular to both and such that the triple forms a left-handed system.
Cross product (part 3)
Unit vectors
These products are right-handed. Left-handed products include a minus sign, such as .
Link to original
Exercise
12
Link to originalCross product via unit vectors
Compute the cross product of and using the unit vector cross products.
Cross product (part 4)
Dot-cross norm identity
The dot product and norm of cross product satisfy a simple relationship:This identity follows quickly from the angle formulas for dot and cross products.
Link to original
Triple products
Triple products
There are some general facts about products taken with three or more vectors.
Dot-cross triple product
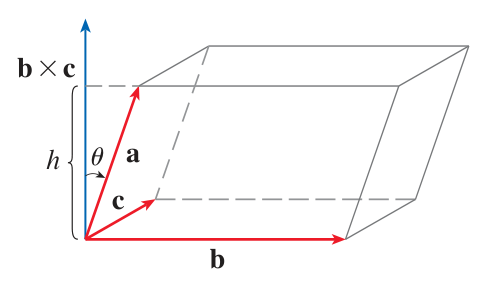
Given vectors , , , consider the scalar quantity . By combining the effect of the dot product with the determinant formula, we have a determinant formula for this scalar:and this formula immediately implies equalities among possible triple products:
(To figure the signs: right-handed triples are equal, and left-handed triples are equal, and right and left differ by a sign.)
The determinant formula also implies a geometric interpretation of the dot-cross product: is the volume of the parallelepiped spanned by , , .
Cross-cross triple product
Given vectors , , , we can form the triple product . (One should maybe not try to think about this product geometrically. It does arise in electromagnetism.) There is a useful shortcut called the Lagrange triple product identity for computing this product:The abnormal order on the right (vector then scalar coefficient) facilitates a famous mnemonic: “Bac–Cab”.
Link to original
Exercise
13
Link to originalJacobi identity
Use the Lagrange triple product identity to prove the Jacobi identity:
Triple products (part 2)
Link to originalNon-associativity
While the cross product is not associative, the difference has a simple expression using the dot product:
This identity can be proved using the Lagrange triple product identity.
Geometric applications of vectors
Lines and planes
Lines and planes
Lines
Given a point identified with a vector and a direction vector , the line through in direction is given parametrically by the formula:Given two points and , the line passing through these two points is given parametrically by:
The line segment from to corresponds to . The point may be considered to be a weighted average of and with weights and .
Planes
A plane in can be determined as the points satisfying a single linear equation, such as:Other formulations of this equation can display more meaning.
A plane is determined in vector form by the data of a single point through which it passes together with a normal vector that is perpendicular to the plane. The equation of the plane can be formed by simply stating that vectors in the plane from are perpendicular to :
If we have components and and , then this formula can be rewritten as:
This equation implies that the , , in the linear equation of the plane are just the components of its normal vector .
Link to original
Exercise
01
Link to originalVector plane from scalar plane
Find the vector equation of a plane with scalar equation .
Exercise
02
Link to originalScalar plane from vector plane
Find the scalar equation of a plane passing through and with normal vector . (Start with the vector form.)
Exercise
03
Link to originalLine and plane intersection
Find the point at which the plane and the line intersect.
Exercise
04
Link to originalAngle between planes
Find a formula for the angle formed between two planes. Use this formula to find the angle between the planes passing through with normal vectors and , respectively.
Distances
Distances
Point to point
The distance between and (more accurately, between the point identified by and that identified by ) is .Point to line
The vector from a point to a line , namely to the point on the line closest to , is given by taking the vector from to and removing the component parallel to :The distance from to is then .
Projection gives minimal distance
One can verify the formula for by minimizing the squared distance from to using the standard calculus technique.
Point to plane
The vector from a point to the plane through with normal vector (that is, to the nearest point on the plane) is given by projecting onto , that is:So the distance from to this plane is:
Plane to plane
Link to original
Exercise
05
Link to originalDistance between parallel planes
Find the distance from the plane given by to the parallel plane given by .
Quaternions
Introduction
[Optional material.]
One can combine 3d vectors and 1d scalers into 4d quantities called quaternions, and written . Quaternions can be added and multiplied and divided.Quaternions have real number coefficients for each of four basic units:
The coefficient is called the scalar part and the coefficients are together called the vector part of the quaternion.
Multiplication rules
Multiplication for , , follows the cross product rules (written formerly using etc. instead), with an additional rule for squares:Using these rules, one can multiply any quaternion sums.
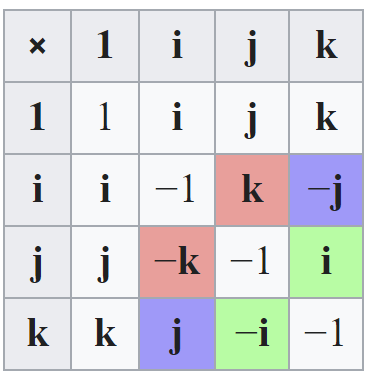
Multiplication charts
If two vector quaternions (with zero scalar part) are multiplied, then the resulting scalar part is the negative dot product, and the resulting vector part is the cross product, of the vector parts considered as vectors using their components.
Quaternions can also be divided:
Link to original
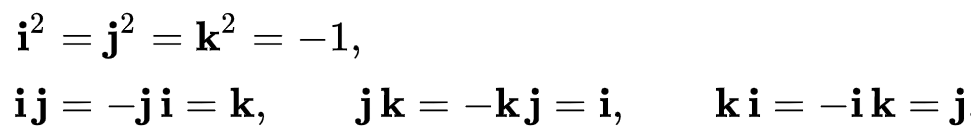
Surfaces: basic examples
Introduction
Quadric surfaces are given in as the set of points satisfying a quadratic equation in three variables. The most general form of equation is:
After applying a rigid motion to , any such equation can be converted to one of these simpler equations:
The surfaces satisfying Equation (1) include spheres, cones, cylinders, ellipsoids, and hyperboloids. The surfaces satisfying Equation (2) include elliptic paraboloids and hyperbolic paraboloids.
The surface type can be deduced from the coefficients or .
One way to study equations of quadrics is to consider their traces, which are conic sections in two variables given by setting the third variable constant. A trace is the intersection of the quadric surface with the plane determined by the constant variable.
Link to original
Exercise
01
Link to originalTranslating away linear terms of a quadric
Show how you can eliminate the linear part from the general equation of a quadric by completing squares.
Introduction (part 2)
Link to originalRotating away cross-variable terms of a quadric
Libretext link for an explanation of how to eliminate cross-variable terms by applying rotations.
Spheres
Spheres
The general equation of a sphere in with center at and radius is given by:
This equation is justified by the generalized Pythagorean theorem for three dimensions.
Spherical coordinates parametrize a sphere at radius . The angle is the standard angle in the -plane, and the angle measures declination from the north pole. These coordinates may be converted to standard coordinates:
Link to originalWarning
Note that give coordinates for points in , but the numbers are not vector components. Do not perform vector operations componentwise on !
Cylinders generalized
Cylinders generalized
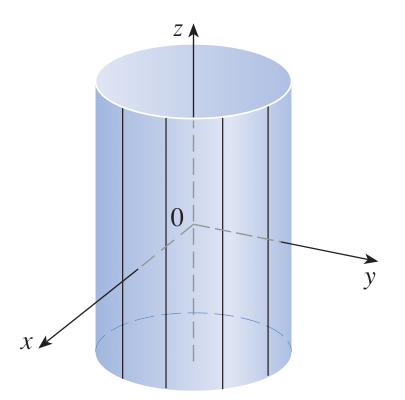
A simple cylinder is a tube extended in the -coordinate with a circle for each -cross-section. No constraint on the -coordinate is needed, and the -coordinates satisfy the equation of a circle: .
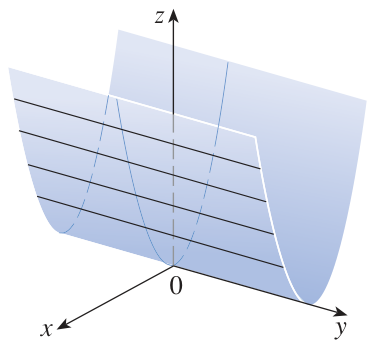
More generally, the set of points satisfying an equation in terms of only two variables gives a generalized cylinder, extended in the coordinate of the missing variable. For example, gives a parabolic cylinder extended in the -coordinate:
For any cylindrical surface, it is possible to find new coordinates in which the surface is defined using only two of them.Note that quadric surfaces written with two variables are generalized cylinders, but most generalized cylinders are not quadratic!
Link to original
Exercise
02
Link to originalDescribe surfaces
Describe the surface accurately using as few words as possible:
- (a)
- (b)
- (c)
- (d)
- (e)
Exercise
03
Link to originalDescribe surfaces
Describe the surface accurately using as few words as possible:
- (a)
- (b)
- (c)
- (d)
- (e)
Exercise
04
Link to originalSurfaces: rectangular to spherical coordinates
Find an equation in spherical coordinates of the form for the following surfaces given in rectangular coordinates:
- (a)
- (b)
- (c)
- (d)
Ruled surfaces
Ruled surfaces
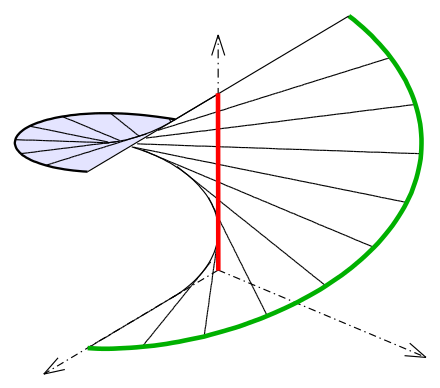
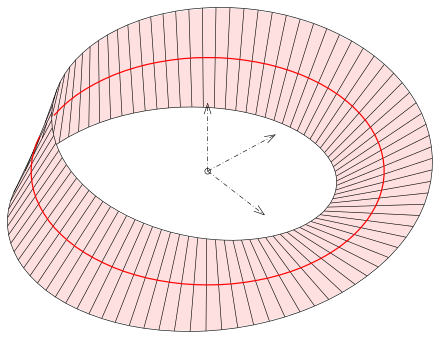
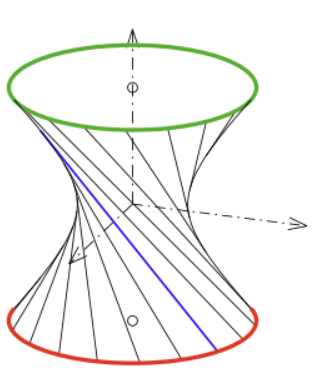
Generalized cylinders are examples of ruled surfaces, which are surfaces created by the smooth motion through space of a straight line. For generalized cylinders, the lines must remain parallel, i.e. the motion must be perpendicular to the lines.
Other ruled surfaces that are not generalized cylinders:
Helicoid:
Mobius strip:
Hyperboloid:
Link to original
Quadrics: ellipsoids
Quadrics - ellipsoids
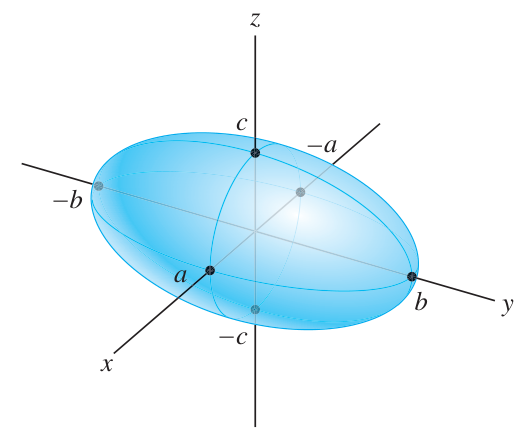
Ellipsoids are quadrics surfaces of type with and .
Under these conditions, the quadric equation can be rewritten into a more expressive form:
As with an ellipse, the constants determine the three axis lengths of the ellipsoid. When , the ellipsoid is actually a sphere.
Link to original
Quadrics: hyperboloids
Quadrics - hyperboloids
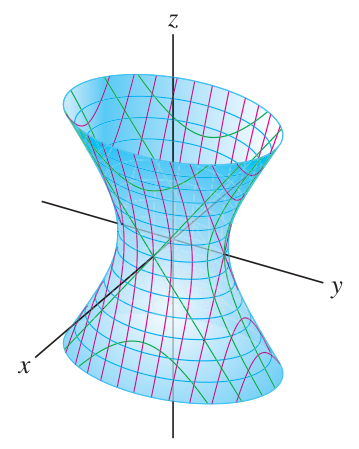
Hyperboloids are quadric surfaces of type with one of less than , and the other two greater.
By exchanging the roles of and rewriting, we can assume the equation takes the form:
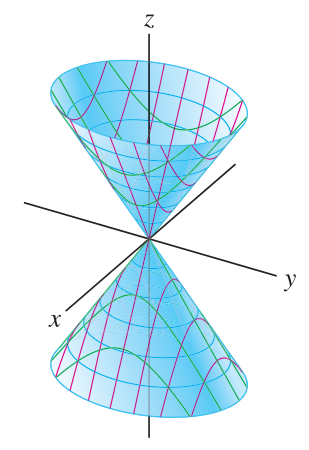
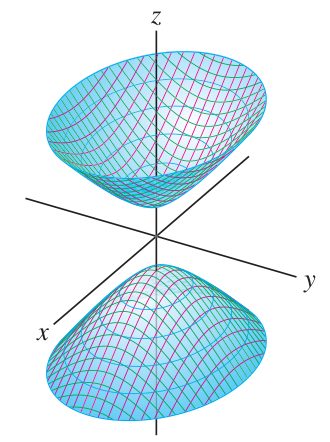
There are three kinds of hyperboloids: cones, hyperboloids of one sheet, and hyperboloids of two sheets. They are given by equations with , , and , respectively.
One-sheeted paraboloids include a circle at , which is possible because . Shrinking shrinks the circle at until it is a point at (creating a cone, or more descriptively, a double-cone), and when goes negative, the surface does not exist at .
:
:
:
Link to original
Quadrics: paraboloids
Quadrics - paraboloids
Paraboloids are quadric surfaces of type . For this type, , so we may divide by and thereby assume . We can rewrite the general form:
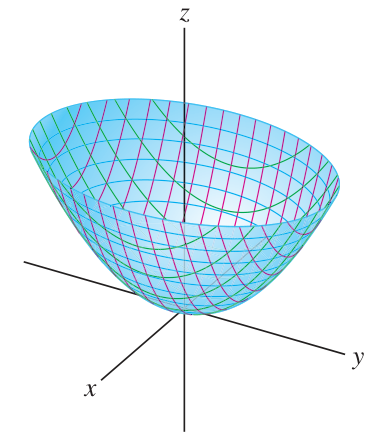
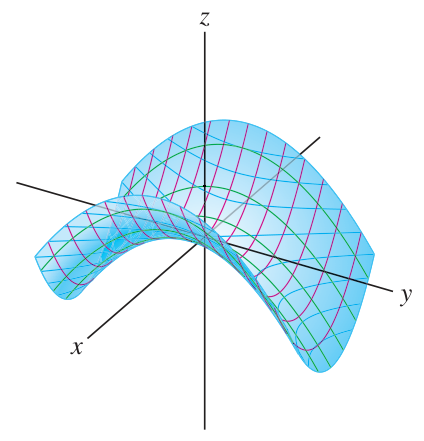
The paraboloid is elliptic when both signs are plus (opening up) or minus (opening down). The paraboloid is hyperbolic when the signs are opposite.
Elliptic and hyperbolic paraboloids are often useful to illustrate optimization methods. A paraboloid has a horizontal tangent plane at the bottom (both signs positive), or the top (both negative), or the saddle point (opposite signs).
:
:
Link to original
Exercise
05
Link to originalHyperboloid with circular traces
Suppose a hyperboloid is such that every intersection with a horizontal plane is a circle. Give a simplified form of the general equation for such a surface.